BeagleConnect QuadESC brings four motor-control channels onto one board
BeagleConnect QuadESC combines control electronics and four motor-power stages on one board. A four-wheel robot builder could use it to command a motor at each wheel. The design still needs suitable control software and thermal checks before motor operation.
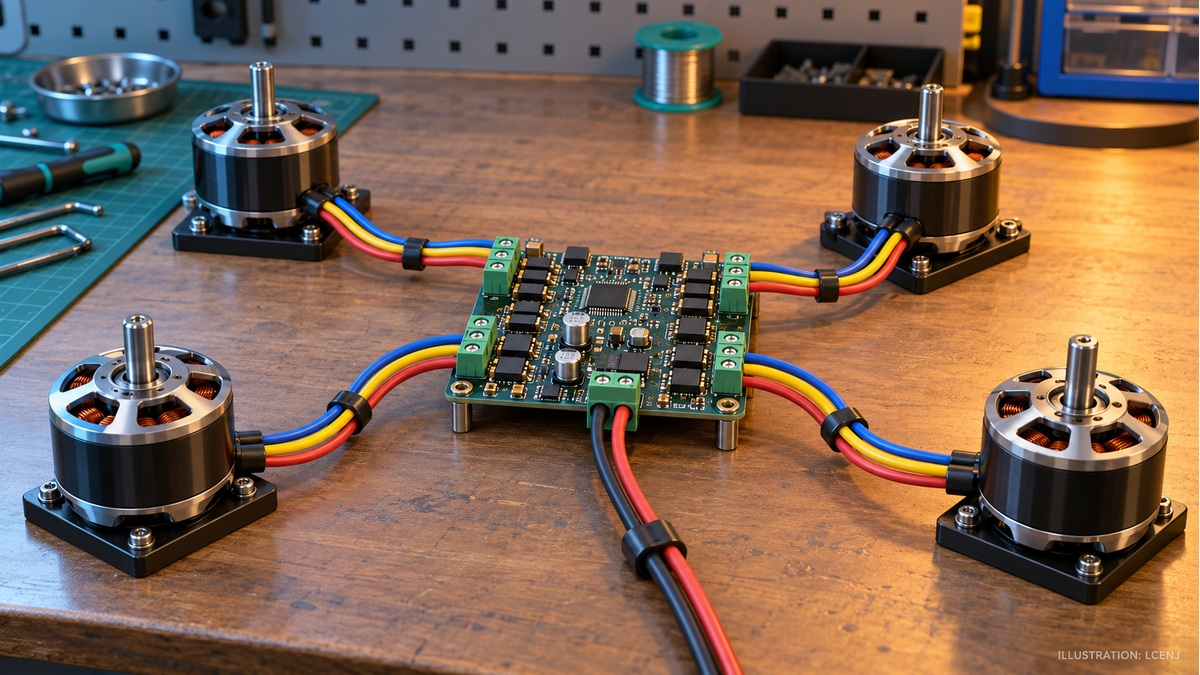
Four small motors with separate wires connected to a conceptual controller on a workbench.
View full-size imageWhat has been introduced?
BeagleBoard presents QuadESC as a circuit board: a physical support for connected electronic parts. Four power stages direct electricity to four motors, while a small programmable computer called BeagleConnect Torque coordinates their commands.
Why measure the motors?
The hardware can measure motor current and nearby board temperature. A program could use those readings to study a wheel under increasing load. The measurement circuitry supplies information; it does not provide a finished diagnostic program.
What remains unproven?
Motor operation requires suitable application firmware. The manual lists 40 amperes continuously and 70 amperes briefly as design targets, not established operating ratings; amperes measure electric current. Cooling and load duration affect the usable current, and no duration is specified for the brief-current target.