Microchip ATFCD52 supplies touch data for robotic grippers
Microchip has introduced ATFCD52, a component that turns changes in a robot hand’s touch-sensitive surface into digital data. A controller could use that information to estimate contact forces and detect the start of a slip—for example, when adjusting its grip on soft fruit. Whether the fruit stays secure and undamaged also depends on the sensor and control software.
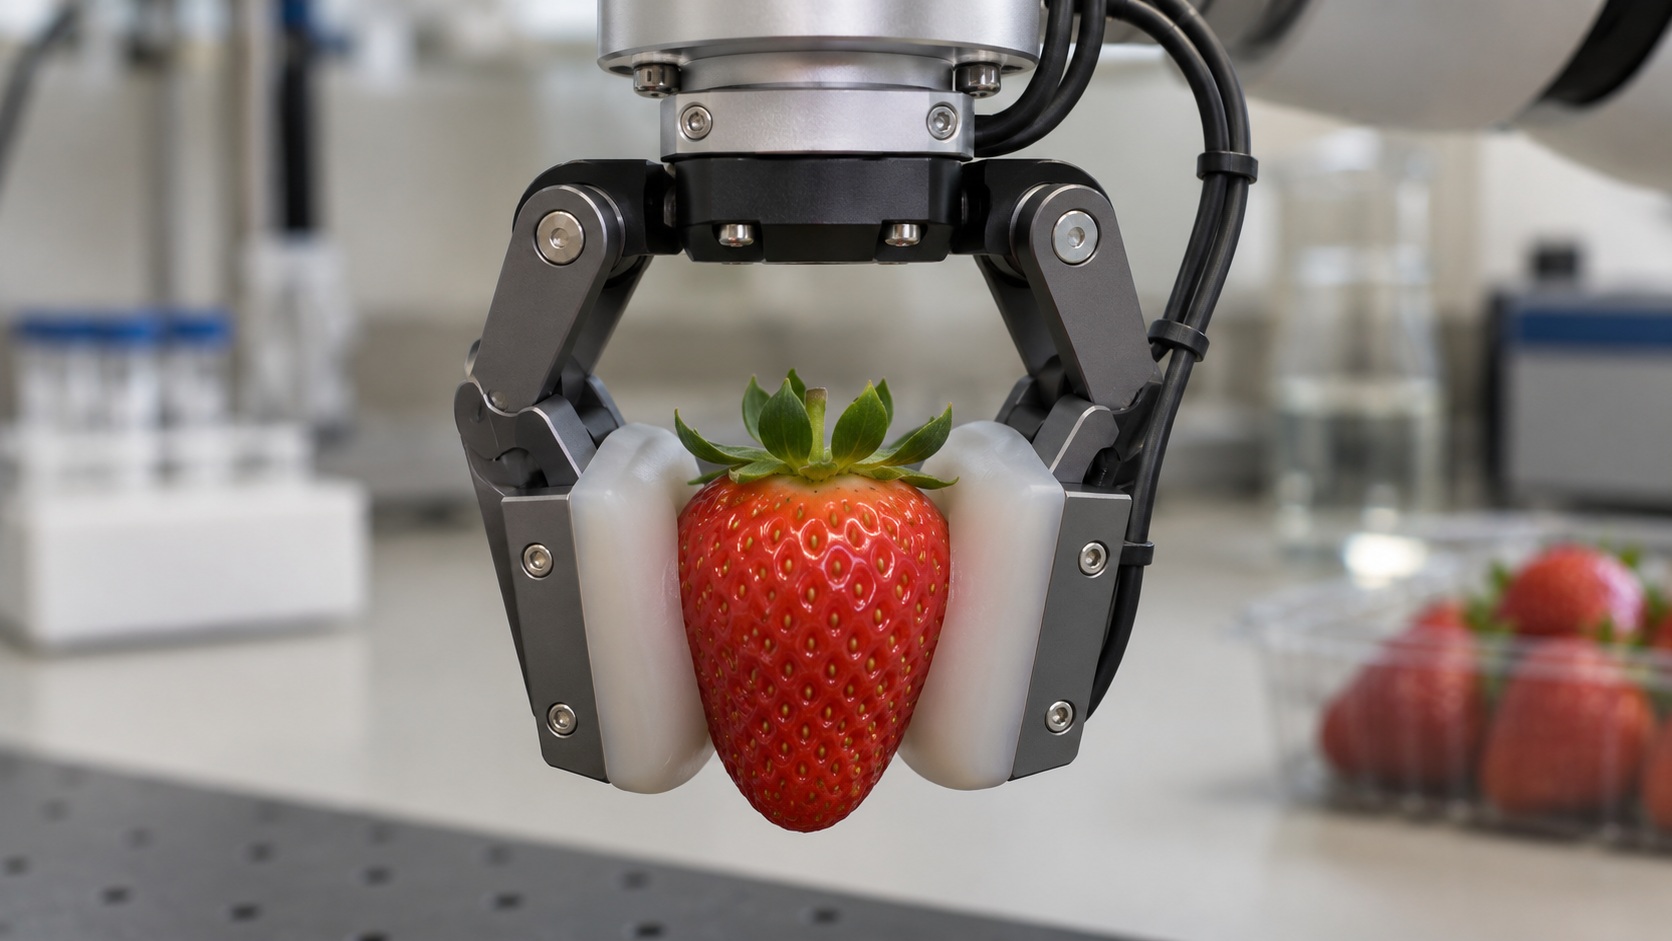
A two-finger robotic gripper holds a strawberry between soft contact pads.
View full-size imageTurning contact into useful information
A sensor measures a physical change. In this kind of capacitive sensor, pressing a soft layer changes how much electrical charge parts of the sensor can store between them. ATFCD52 reads those changes. A separate processor must turn its output into force estimates and decisions about gripper movement.
What is available?
Microchip announced the part on 10 November 2026, and its product page lists it as in production. The technical overview specifies up to 800 complete readings per second for a 10-by-10 sensor matrix; that rate should not be assumed for every array size.
The EV-ATFCD52 kit includes a 10-by-10 sensor and data-viewing tools for evaluation. It does not replace calibration—comparing the output with known forces—or testing the complete device.